|
|
马上注册,结交更多好友,享用更多功能,让你轻松玩转社区
您需要 登录 才可以下载或查看,没有账号?立即注册

×
APT刀轨数据生成NC程序C++源代码,本功能仅作为技术交流研究之用,代码,功能可能存在缺失。需自行编写刀轨数据的读取与处理。以下仅为部分代码以下为头文件部分源代码- int EQ_is_equal (double s, double t);
) d$ c' J: b) D$ V - int EQ_is_ge (double s, double t);
7 G6 w. }5 e: k+ j! R - int EQ_is_gt (double s, double t);
$ K- S0 o& O+ B. l. w, e - int EQ_is_le (double s, double t);
" b; U- v' }0 w, s$ \2 |2 E - int EQ_is_lt (double s, double t);
) r' E0 }7 e+ c# `$ I, d* o - int EQ_is_zero (double s);* D* `6 f/ K# m8 A: j. E
- //=============================================================" Q) q- i$ p* [/ m* y
- double ARCTAN1 (double y, double x );
" @1 s+ [; D- c/ D# v - //#=============================================================
- J2 Z7 W& b5 o% n* O! r' w - double ARCTAN2 (double y, double x );9 r' ?" ~4 y& y: M$ q/ R
- //#=============================================================
+ R7 F- q m l& q8 o- _ - double CheckConst ( double angle, double constvar );% @$ X$ D/ Z9 a" J: Q& }5 z* g
- //#=============================================================
4 q1 ^' L) p# t6 X$ Q - double Check360 ( double angle );! N3 z: A+ b, @0 J3 M4 g7 O
- //#============================================================= s; W. G# u& Q" K" F0 F
- double CheckLimit ( double angle, double kin_axis_min_limit, double kin_axis_max_limit );
' v; Y! `( b8 v4 V* n1 X" e - //#=============================================================
以下为部分源代码,用于判断,计算角度等
/ d' B5 B H& j* z& g3 [( s4 m- int EQ_is_equal (double s, double t)6 q. t( Z. m4 ?' k/ e" U
- ! ~6 F x, Q2 ~8 A( P3 M; ]
- {6 Q3 M8 i. @% I9 _0 J
- , S9 R8 [! u: l# _2 T
- if (fabs(s-t)<= system_tolerance) { return(1); } else { return(0) ; }
- l4 e9 r# e& h6 D' D - . w' H: K$ @: A/ G
- }
7 N w5 b. H% _
4 W7 l9 J- o. U- /***********************************************************************/
+ u% N& G, R) V
8 E0 X) f+ l8 p- int EQ_is_ge (double s, double t)1 Q+ D; p" u+ ]$ R
- : P4 [9 r6 s8 q# N$ a) G
- {1 k! e3 Y g+ b% y
0 M# [- [2 o* j( @0 s Q x- if (s > (t - system_tolerance)) { return(1); } else { return(0) ; }
9 k- g1 n/ l+ V- @
! g0 [' _5 A& t- }& l! ?; U; q5 {! K9 c4 Q# K& ]
- 3 w4 K! n$ @' m: b
- /***********************************************************************/ _; P- Y% g/ R5 f+ A
- 5 o$ ]9 T* _4 L: V! |5 ~" Y" k% X5 N
- int EQ_is_gt (double s, double t)
8 X6 |6 L' J2 h& b - # o, m% ~! R6 F* o: f& Z
- {: y* U/ j5 z; t. K* {) k+ {) @
- ' C, f7 @7 ~( G" I- `0 x4 H
- if (s > (t + system_tolerance)) { return(1); } else { return(0) ; }' I# ^' a- w) G4 x4 Y+ b* S2 C% s+ ~
" `0 k" y/ D5 J8 X' W* J h4 e- }
, m9 m9 o |: n& g6 ^% m7 J
I# | z* y0 T- Y% l- /***********************************************************************/
4 T0 }1 r3 J# z6 ~9 e2 S
7 p/ N9 C! f# H% m8 J- int EQ_is_le (double s, double t)
+ w3 n; ~0 y) o6 O b. r6 O - 2 `, F# r$ W1 i8 j6 M
- {
( ]- R4 }, `: L& q. F& }3 {5 Y) T
) n1 `( L. d3 C6 {- W$ S1 e- if (s < (t + system_tolerance)) { return(1); } else { return(0) ; }& s6 u* `8 y& J
- 9 {' O3 [2 z4 }( }# j2 y) Z0 n: O) J
- }
4 K+ S% V) k' c: _0 T - 4 H+ U$ w! c. @7 a6 G; q6 G* W
- /***********************************************************************/
; Y# B$ D9 g; g; |8 w# X# _8 q - ; e9 b2 ?' r+ H6 C4 u8 m4 f
- int EQ_is_lt (double s, double t)
- D, W6 @* z8 ~2 q4 {: [
H; }; ?" ]6 y( n: y- {/ j* W3 _0 c! c7 z' p0 o. I0 C2 f
4 T* ~8 f7 b0 E- if (s < (t - system_tolerance)) { return(1); } else { return(0) ; }
* s) ]7 j, O& _3 m - . I' m1 C: p" F( I& [
- }) v, ~$ @: q$ A0 t% J/ w
- # W8 q. X4 r1 f* s
- /***********************************************************************/8 W: i6 ^% @6 i3 }' \
- " W4 `+ |* X3 g5 |' Q% ]$ `& v- ~
- int EQ_is_zero (double s), @. x* Z$ b) W: }' i" v
- . d3 L0 o/ l* X
- {
$ V% M/ Z @" K# `0 `5 h5 f
: \8 B9 \' b- K- ~9 O- if (fabs(s)<= system_tolerance) { return(1); } else { return(0) ; }
M; R1 z3 u$ a3 V# j# i% F1 E6 b - $ N: w; Z/ z$ ~: Z9 O
- }
0 d+ G7 \, S# i6 v, n - . Z5 i7 ]% S5 N
- //=============================================================
3 q" J3 c1 U X2 L; k
" ?2 T0 {% q% a% r6 E8 ^- double ARCTAN1 (double y, double x )
7 w/ }! ]$ z; f( u' C' }5 A - 9 a, d& n' T5 ~& t
- //#=============================================================. G4 W) A( t l, \/ G/ G% P
+ Z" Y; W. @0 h0 Q& A# ^- {5 ^6 f6 O+ j7 @5 L: B8 n
- ; L0 A6 a3 d+ E& E4 h
- double ang;/ B' |* i: N+ X5 {$ o$ \" g3 {' C9 y
* o) q) U& m w R# u% S. p- if (EQ_is_zero(y)) { y=0; }) n+ U. Z. V* O0 W
- - C1 Q2 X8 B" `, V" L
- if (EQ_is_zero(x)) { x=0; }6 o& B" ~. g; Q0 }/ c
$ v9 K9 F+ j3 N; V" j% l: P8 E; A- if (y == 0 && x == 0) { return(0); }$ s6 p2 Y H' C# v1 w
# K8 A1 W% A1 I' i( q& U- d- ang=atan2(y,x);
/ H) g9 J8 o" V7 `( I6 L. ]; _ - - V; W$ r. D) n4 B; W
- if (ang < 0 ) {
+ u6 ], ^) N x+ x$ o4 ?2 s2 n) A
8 R l3 i, [) T) M. ~- return(ang + PI*2);
* w! K7 p5 g1 |: }' ^ - * z9 J2 f" F9 P7 C( m; m6 V$ q2 O7 c, A
- }
9 O2 K6 R: Z( S$ m) n - 5 P+ F, W b! l/ n" @
- return(ang);* K$ y1 S- \# W
' T6 K. o& |$ S- }
6 C, B) u f2 l) F4 x/ C
, E$ `4 D A& x- //#=============================================================9 F: q$ b8 _' b2 H
- ( R# E( ~5 Y! m g8 l
- double ARCTAN2 (double y, double x )# k) W" Z$ W) g8 {5 @& Y& p
3 \. U' I& o/ {: [# h- //#=============================================================# \ ~$ ~1 `. ?0 \" Z! S$ a2 y# l
- m- l$ x$ G2 t% o- {
3 H; x0 J7 u. | - " x5 _& T7 R/ @8 q3 H) n) E0 m
- double ang;' G2 E) u0 o k( D/ M/ A
* G! e5 B* r" b- n- if (EQ_is_zero(y)) {
U& ~2 x) \: L3 i- I" T' V - 2 `3 p7 H$ C( P5 |6 _* A6 e/ y
- if (x < 0.0) { return (PI); }
" E% Z0 \ T E. \8 y
0 Y' F4 W2 E& R. I! {* K- n- return (0.0);: ]9 _+ }5 G5 C$ O6 ^
- , f4 w# H8 L2 o9 G
- }
0 V6 w9 G" N- @% `* B4 r$ E* \
_0 v. f4 f8 P$ ^- if (EQ_is_zero(x)) {
$ ?, e# R. t; N R2 C - , F6 d% O; G! p) K6 F; i
- if (y < 0.0) { return(PI*1.5); }
) X* g2 t. }9 X- L1 F. D
3 b, b8 n% i/ t# S6 T- return(PI*.5);
7 n& i$ a9 a1 m - ; |# A6 [; R" F9 E0 }; @
- }
* Q" k* J& l/ u
' E# }6 R) M" M! l3 g- ang=atan(y/x);$ h, a* ^ j# e1 [; J
; W! T8 r- W3 W" W4 K- e) t- if (x > 0.0 && y < 0.0) { return(ang+PI*2.0); }5 w7 l' X+ o' }) R
- 3 b' ~9 _# L0 \* ~
- if (x < 0.0 && y < 0.0) { return(ang+PI); }' p$ P4 B* K& }; M) K6 L& B# W
- % c" h4 O7 i+ e3 B; i7 y
- if (x < 0.0 && y > 0.0) { return(ang+PI); }
8 b& M* o {% q. f
; j5 {5 N9 h( V# k Y# H- return(ang);
5 C# t$ u& A, S0 ^
( z% `% `) G- c- }' J: x: n4 ~+ i! @ P' f y j
* s9 x! d- H+ P# v- //#=============================================================
8 R1 Y8 r: ?* n& X - 5 f2 N2 v, p3 y/ H
- double CheckConst ( double angle, double constvar )
0 g; X! v8 M. `4 p l - " g/ m% D6 m& X0 c1 z7 m% R
- //#=============================================================
$ Y t2 S0 m% f* x
- f$ C1 L; e2 ~$ y% x6 y4 I- {* n3 g/ e/ o% x: L0 }3 |2 m$ S
- 8 F3 @$ C* A9 q
- while (angle < -constvar) { angle+=constvar ; }
4 [8 r& B7 k I" a% x- _% G
( {) }! O* n. w8 a- ]# N1 o- while (angle >= constvar) { angle-=constvar ; }
2 A( `7 n0 @# T A/ c
$ j3 w C) q' A1 u2 \# y- return (angle) ;+ L- r$ O/ X' Z) }) r( f
, X: J$ e$ U7 L ?: ?/ @3 z- }/ }# u6 i$ F9 I" p, P
& S+ U: p8 @; w1 N; h! Z0 @, ?/ r7 [- //#=============================================================
% f) U+ a' o5 ^! \$ ?1 l
% t0 H% R; y( v% \1 F5 ]9 ~- A4 c q- double Check360 ( double angle )8 I" Z" x0 s% V. f3 E" u
- & j6 |( a$ r3 x$ d N2 x; E% z
- //#=============================================================$ k# `* l: r; W( k
- - n. ]( p) a- e, h
- {
% C" ~1 X0 T9 m3 I9 |6 r7 ~% M
9 e( g# C" L+ _ o A/ W8 O ~- while (angle < -360.) { angle+=360. ; } Y e0 E# u, h' D9 m8 \8 D
, d5 h8 w q, O' }- while (angle >= 360.) { angle-=360. ; }% Z6 S9 i& w/ l
% @& ?- p- e9 w, |1 O- return (angle) ;
2 ~; @/ T6 I$ X# F/ f4 K9 |$ D - 9 [/ c) j* S! G3 e1 J1 ?6 {2 a
- }
1 @- O( J+ {8 C6 Q: Z
- q8 u; W8 c9 {' _8 t2 h- //#=============================================================
P! L( I: R" ` q" q# i - / _1 K: o. }" d/ t, V
- double CheckLimit ( double angle, double kin_axis_min_limit, double kin_axis_max_limit ). J6 }1 E% d) m& e- Y, }6 o' e" ^
( U! c5 ]( T& L% F; |4 F- //#=============================================================
' d; ]* C; K2 h( x, [ - $ u/ m1 t* V2 s5 T @0 E
- {
% G$ e4 _ V" |' ` B - $ f6 C9 }7 ]7 C0 F- C4 H5 j4 R
- while ((angle-kin_axis_min_limit) > 360.) { angle-=360. ; }
7 n9 o, M' {! t% l2 h% U
0 r. b7 l" V5 W1 Z- while ((kin_axis_max_limit-angle) <= -360.) { angle+=360. ; }
! _. L" b2 `3 A0 ~7 F
, ?6 q* [3 H7 m' P2 {- y/ a& h8 p- return (angle) ;+ K- K; H) e: i& F2 i7 p4 s" J8 r
- # l; s0 I+ c- s: T5 Q7 I
- }
9 M+ k& G& w2 C5 D' Q. q% g以下为摇篮5轴计算过程代码
7 L8 e, O. d+ S2 ]4 {- i=sin(ang_rad[1]); j=0.0; k=cos(ang_rad[1]);: {; O; m& q& T a2 U4 t0 _! x) V
8 \# g$ h" C% q- j=0.; B1=0.; B0=0.;
1 g) M) F! f7 v: Z
( U! [- B3 l* u6 W T) x7 \# t& Y" k- if (EQ_is_ge(i,0.)) {3 R s+ e6 z' K+ u4 C) U0 ?
5 U% `4 [2 h" u B3 y- b- if (EQ_is_gt(k,0.)) { B0=acos(k); B1=B0; } else { B0=acos(k); B1=B0; }
; G" R3 m. T A- I - w3 e. ]" t) w
- }+ }$ z( g: t! c* ?
- ?) G: a" x4 P9 ~
- if (EQ_is_lt(i,0.)) {# B' C' F- C. ?% H l+ [
- ) R3 u% B) P3 k# H8 H; _! i5 Y' Y
- if (EQ_is_lt(k,0.)) {9 x- G: S3 Z' L$ F% X6 s# [
: B8 r$ M, Z1 ]9 s& j5 c6 i* m- B0=atan(i/k); B1=B0+PI ;+ B' K" q, h9 X$ x, O
- & ?4 X+ z/ C% M" U
- } else {% }& w4 q. I; k- G. f
, L; X2 d ?) f {- if (EQ_is_zero(k)) { B0=-PI/2. ; } else { B0=atan(i/k); }
; o# e2 h; E/ @ - 9 k+ n+ a/ ^4 O
- B1=2.*PI+B0 ;
/ G1 Y8 ?9 Q7 R- s- }7 E- W9 | - 9 B" a/ ^) s8 P" e! S( O
- }/ f2 k' s$ j: O- s
1 c& R7 l) O% P' c+ U: c0 A- }; e' ]4 q6 t' j; u8 {1 [
' i8 A, z/ [2 v- if (EQ_is_ge(B1,0.)) B0=1.; else B0=-1. ;9 |$ N; T) B [9 H9 ]
- % G% d$ B: B+ F! z
- B2=(-1.)*B0*(2*PI-fabs(B1));
0 J/ m, m8 S9 F: J - 4 Y& z( @5 G9 k0 g
- ang_rad[0]=0.; ang_rad[1]=B1; ang_rad[2]=0.;
5 U( F2 @4 D& J6 D. Y, J3 I8 o
2 E1 s! ?4 s8 m8 _- ang_rad[3]=0.; ang_rad[4]=B2; ang_rad[5]=0.;
1 b1 _; a9 l) ^8 e- |# B0 |通过输出的NC程序,反向输出的刀轨数据与原始刀轨文件对比,其数据结果一致。6 W- s4 J$ ^( _& b, s
# B( }' G1 e- X+ F4 F7 T9 W
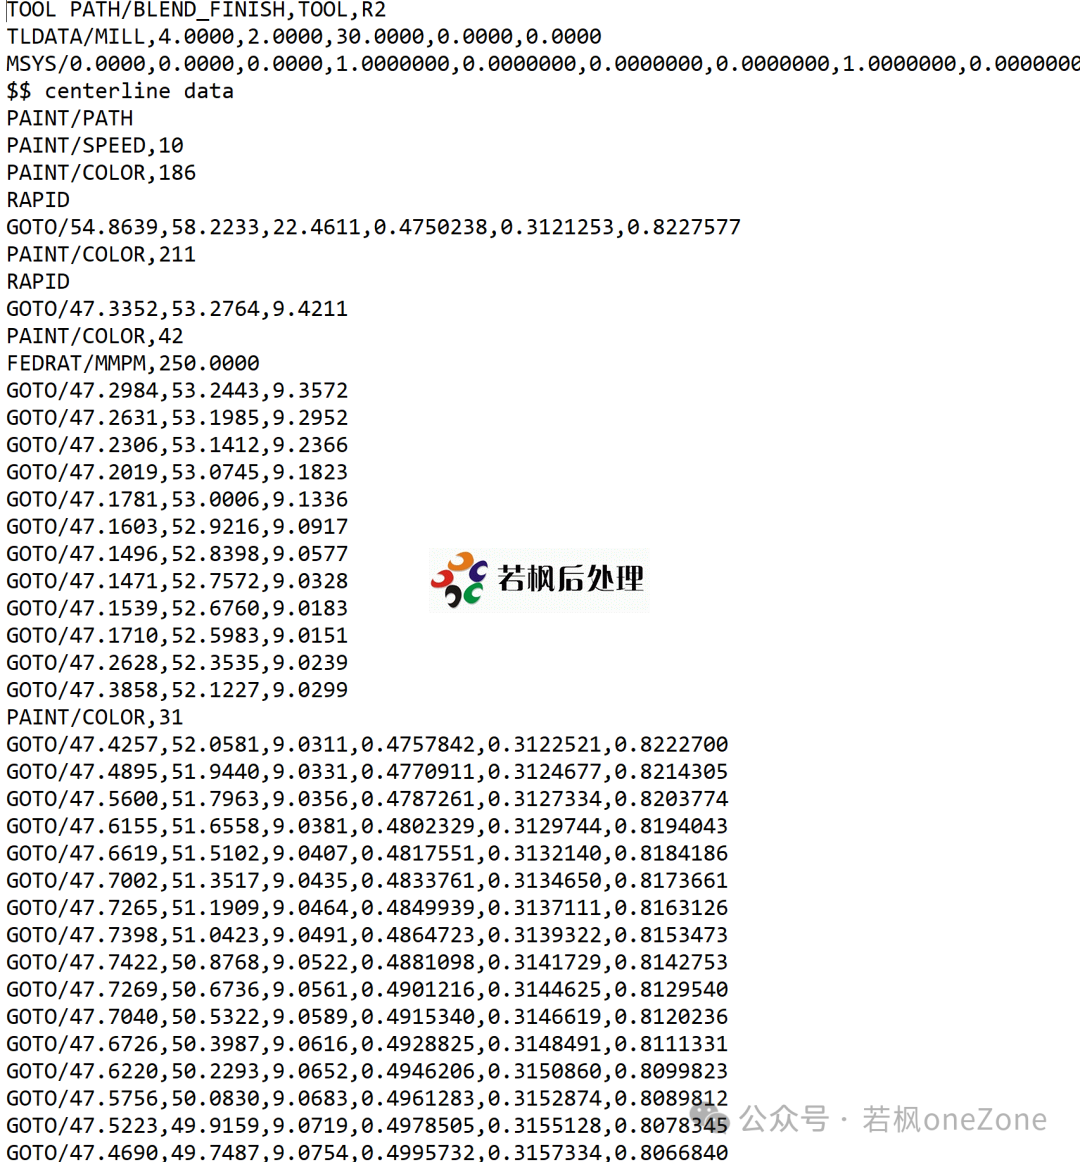 : W! S! {/ l: d9 J9 h0 T$ _+ N. \
测试结果:9 W7 [6 ^( j8 p5 }
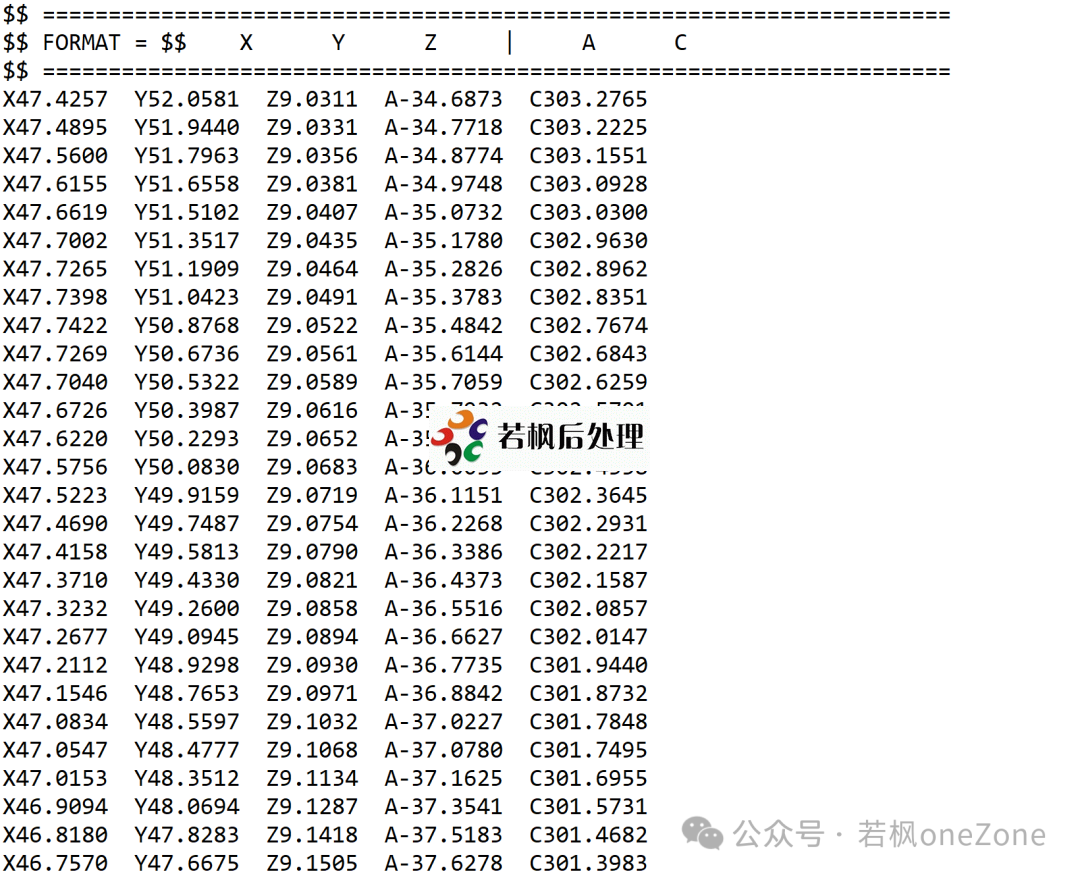 * E/ E8 S% l. D' N
% Q% R- ~& y t: f
反向测试结果
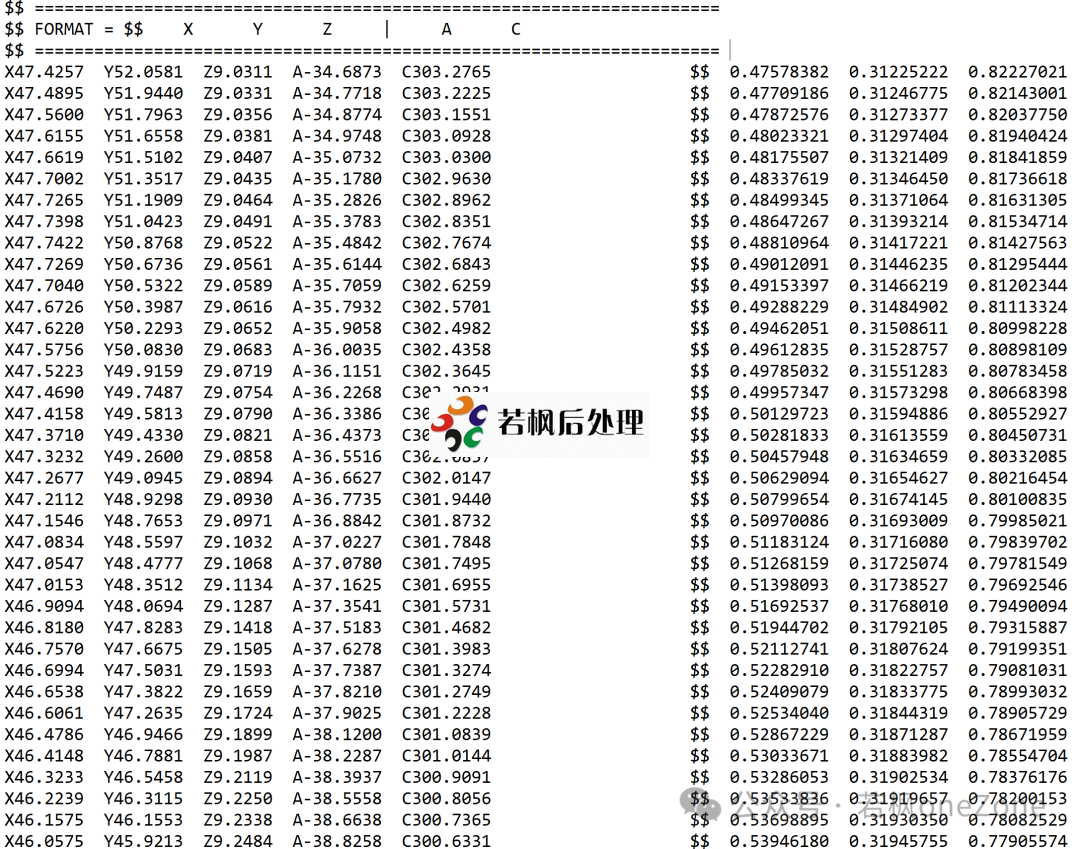 4 k; B; O; Z$ y( T7 N
|
|
 /2

 |Archiver|手机版|小黑屋|若枫后处理论坛
( 苏ICP备11015087号-1|
 苏公网安备32059002001368号 )



 IP卡
 狗仔卡
 发表于 2025-5-21 20:59:21
 提升卡
 置顶卡
 沉默卡
 喧嚣卡
 变色卡
 千斤顶
 显身卡
 发表于 2025-6-3 18:53:03